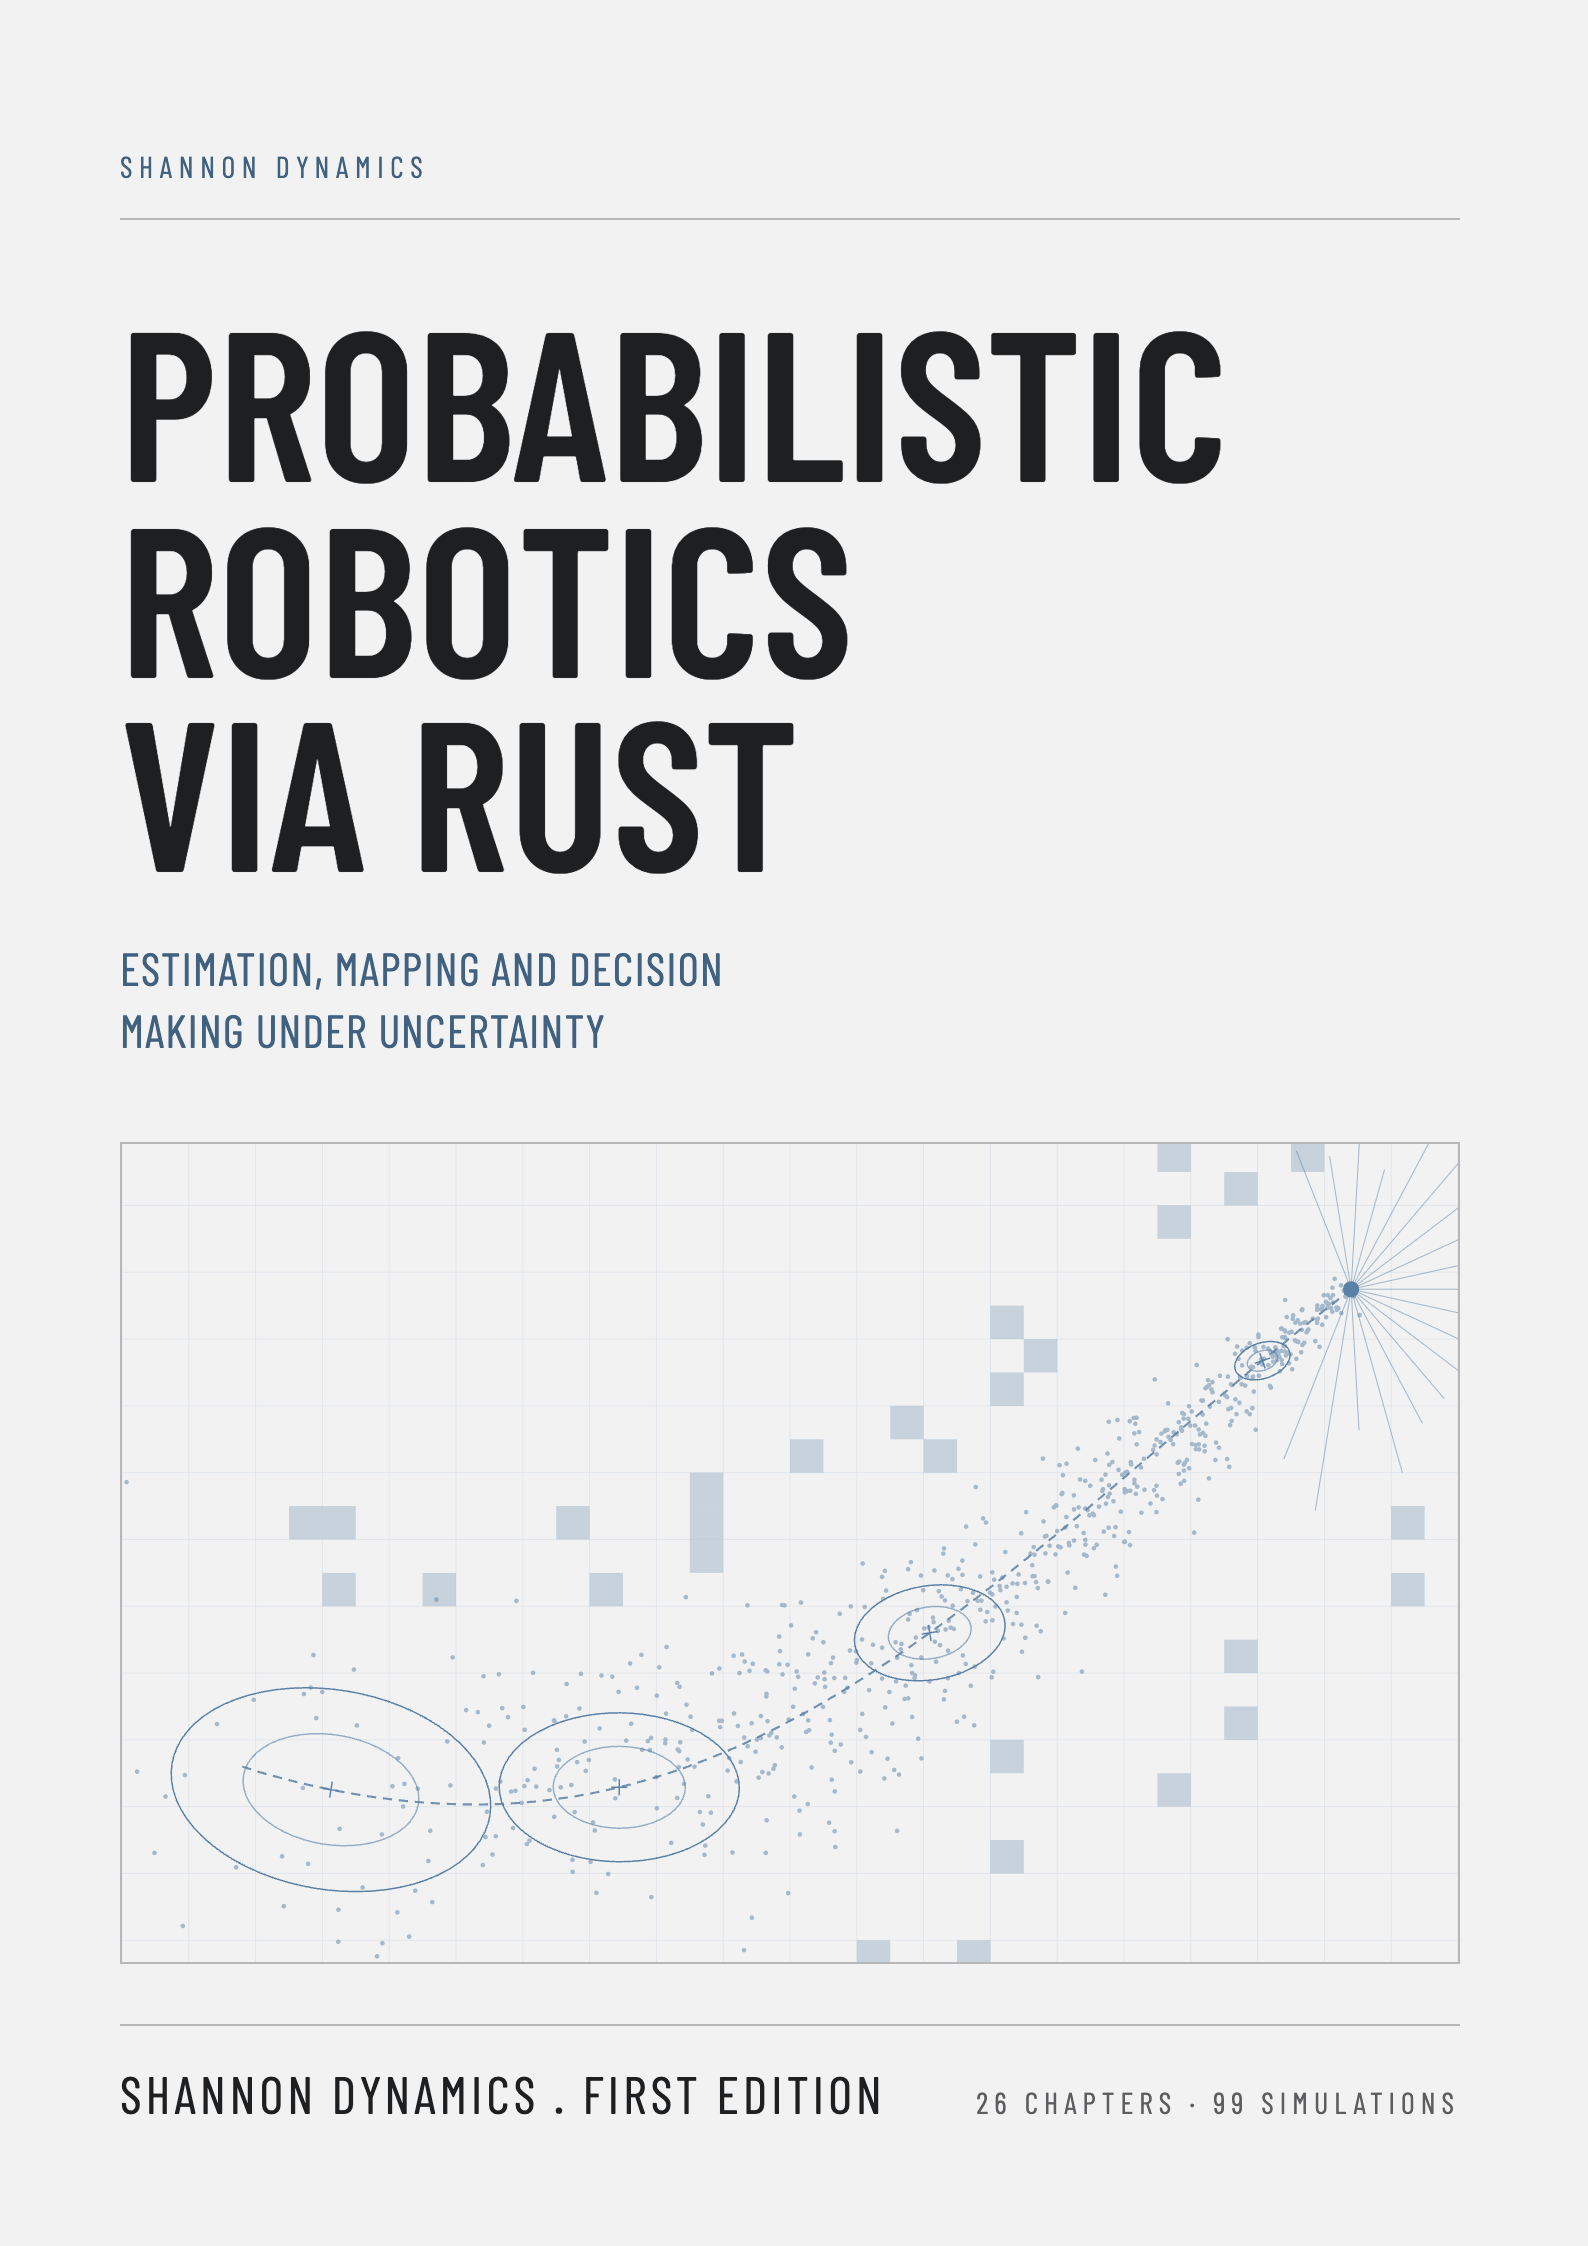
An interactive book on probabilistic robotics — Bayes filters, Kalman and particle filters, localization, occupancy grids, and SLAM as sparse least squares — culminating in a rover that maps a floorplan it has never seen.
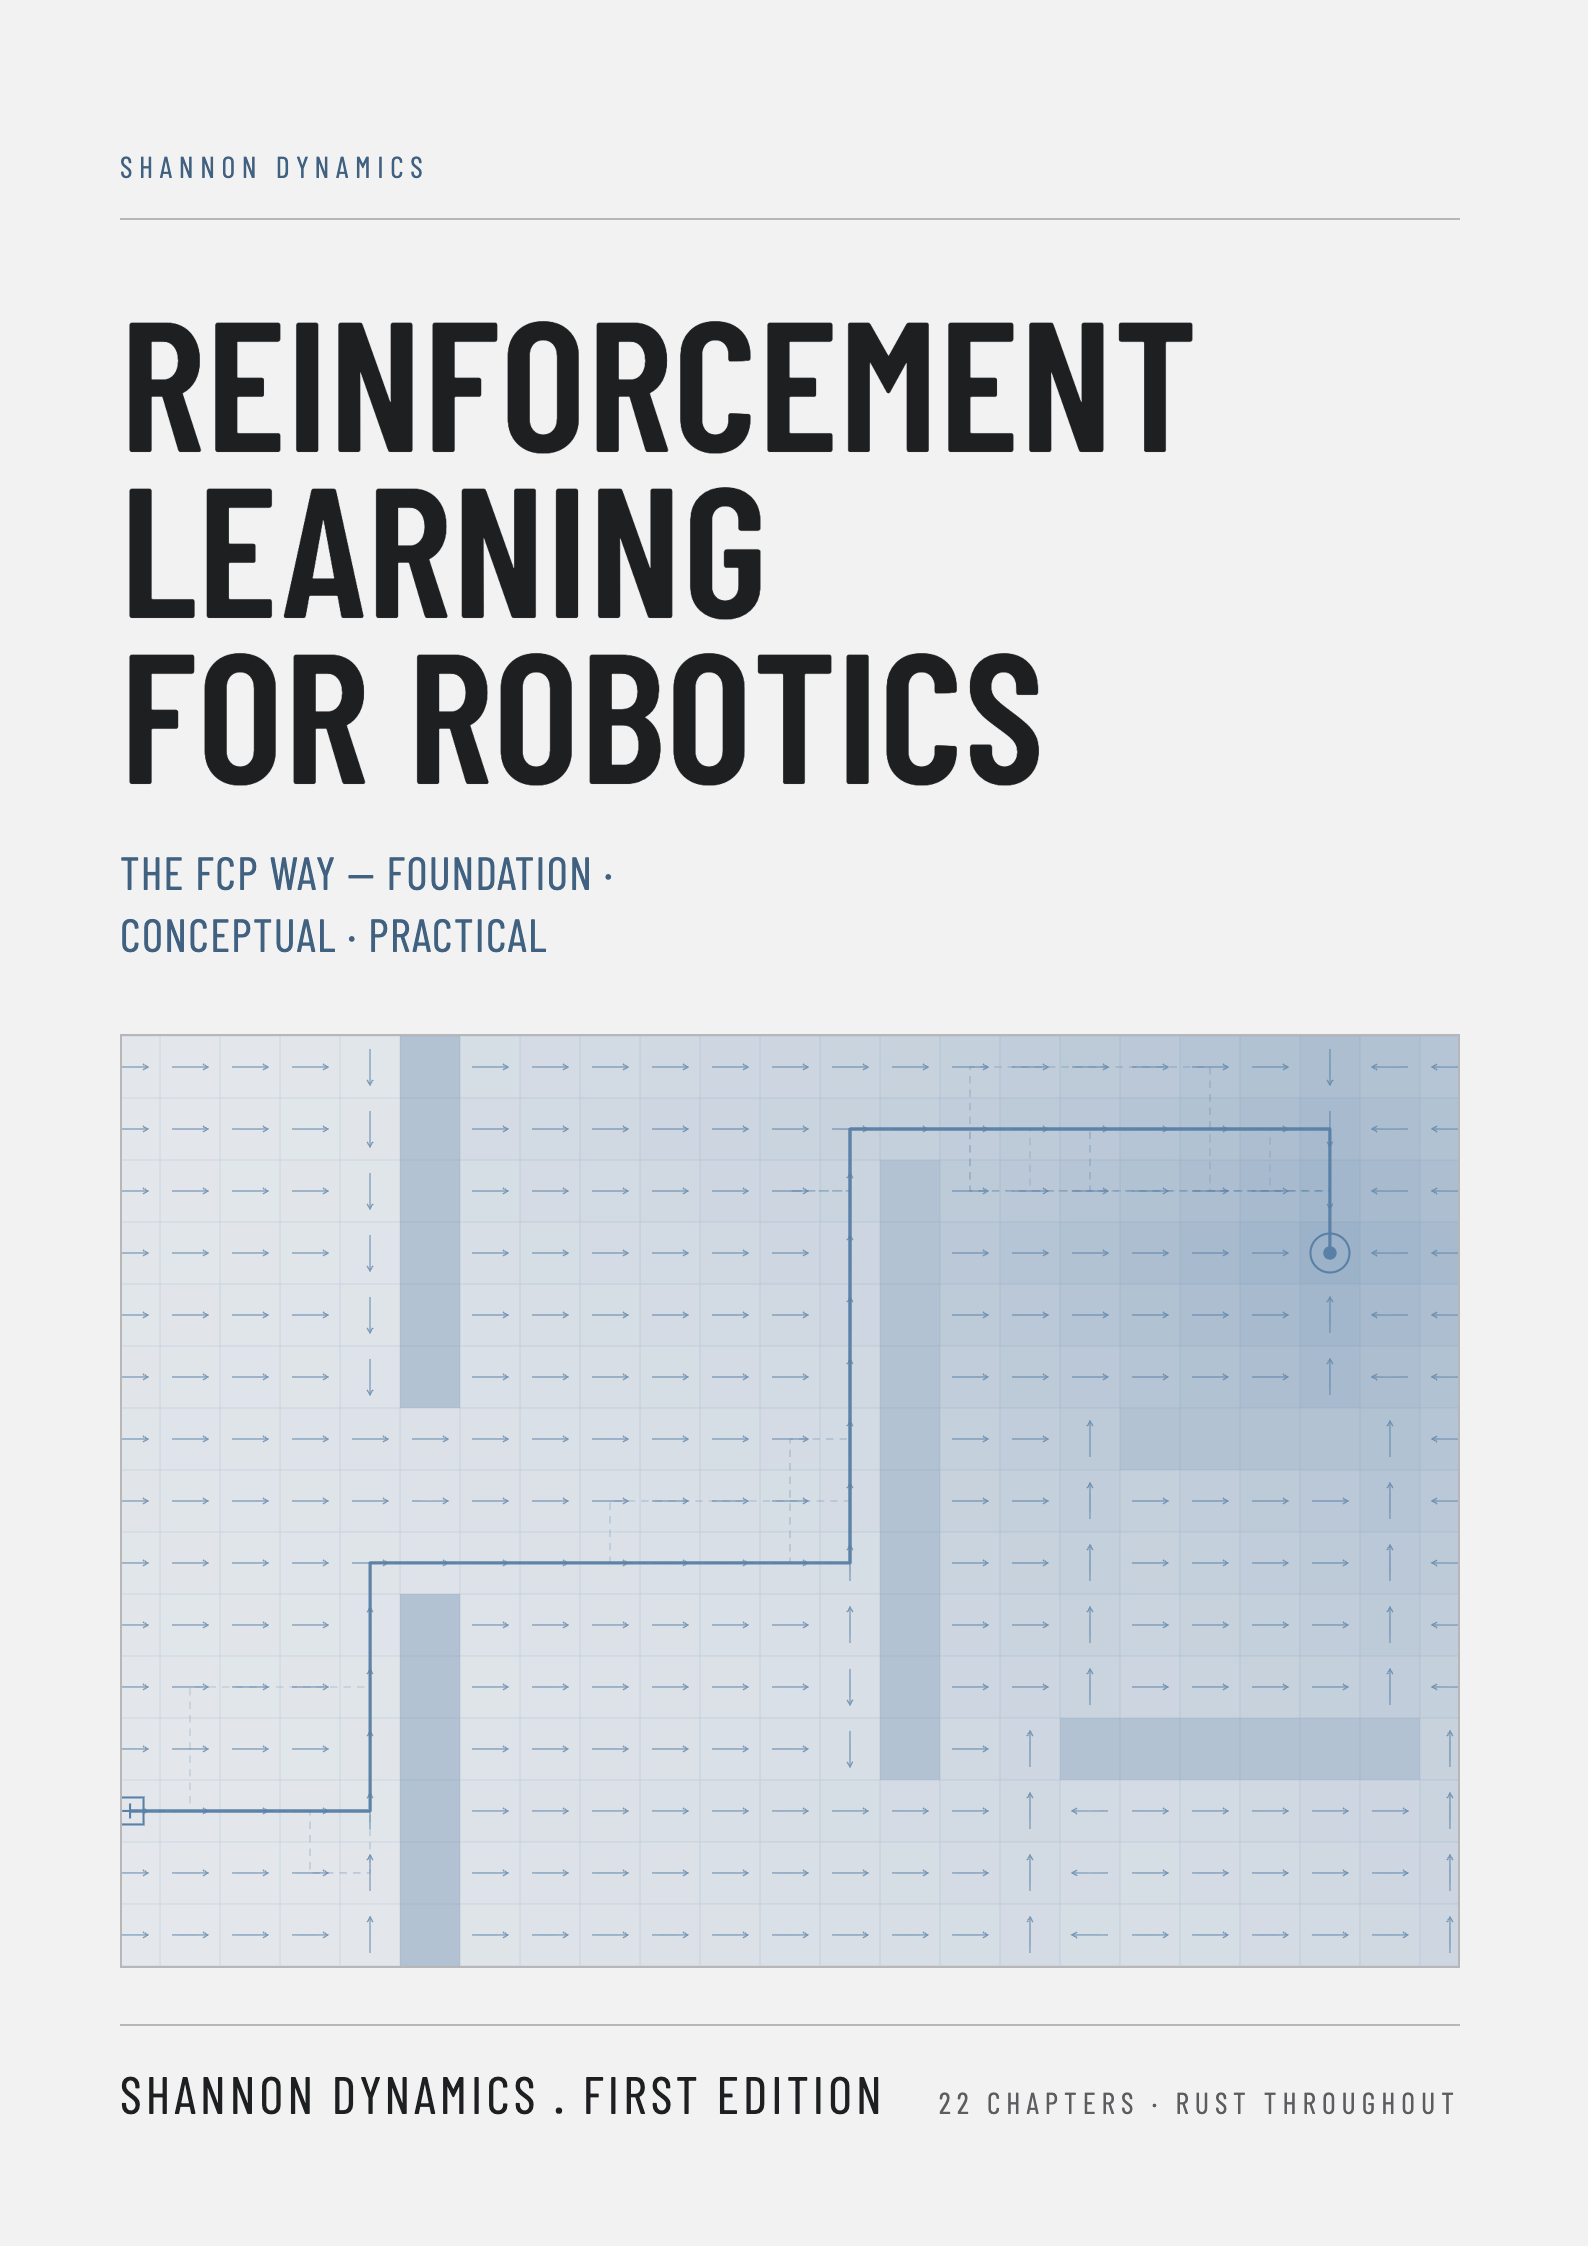
Reinforcement learning for robotics the FCP way — full mathematical foundations, interactive simulations, and production Rust, from multi-armed bandits through PPO/SAC to a quadruped that learns to walk.
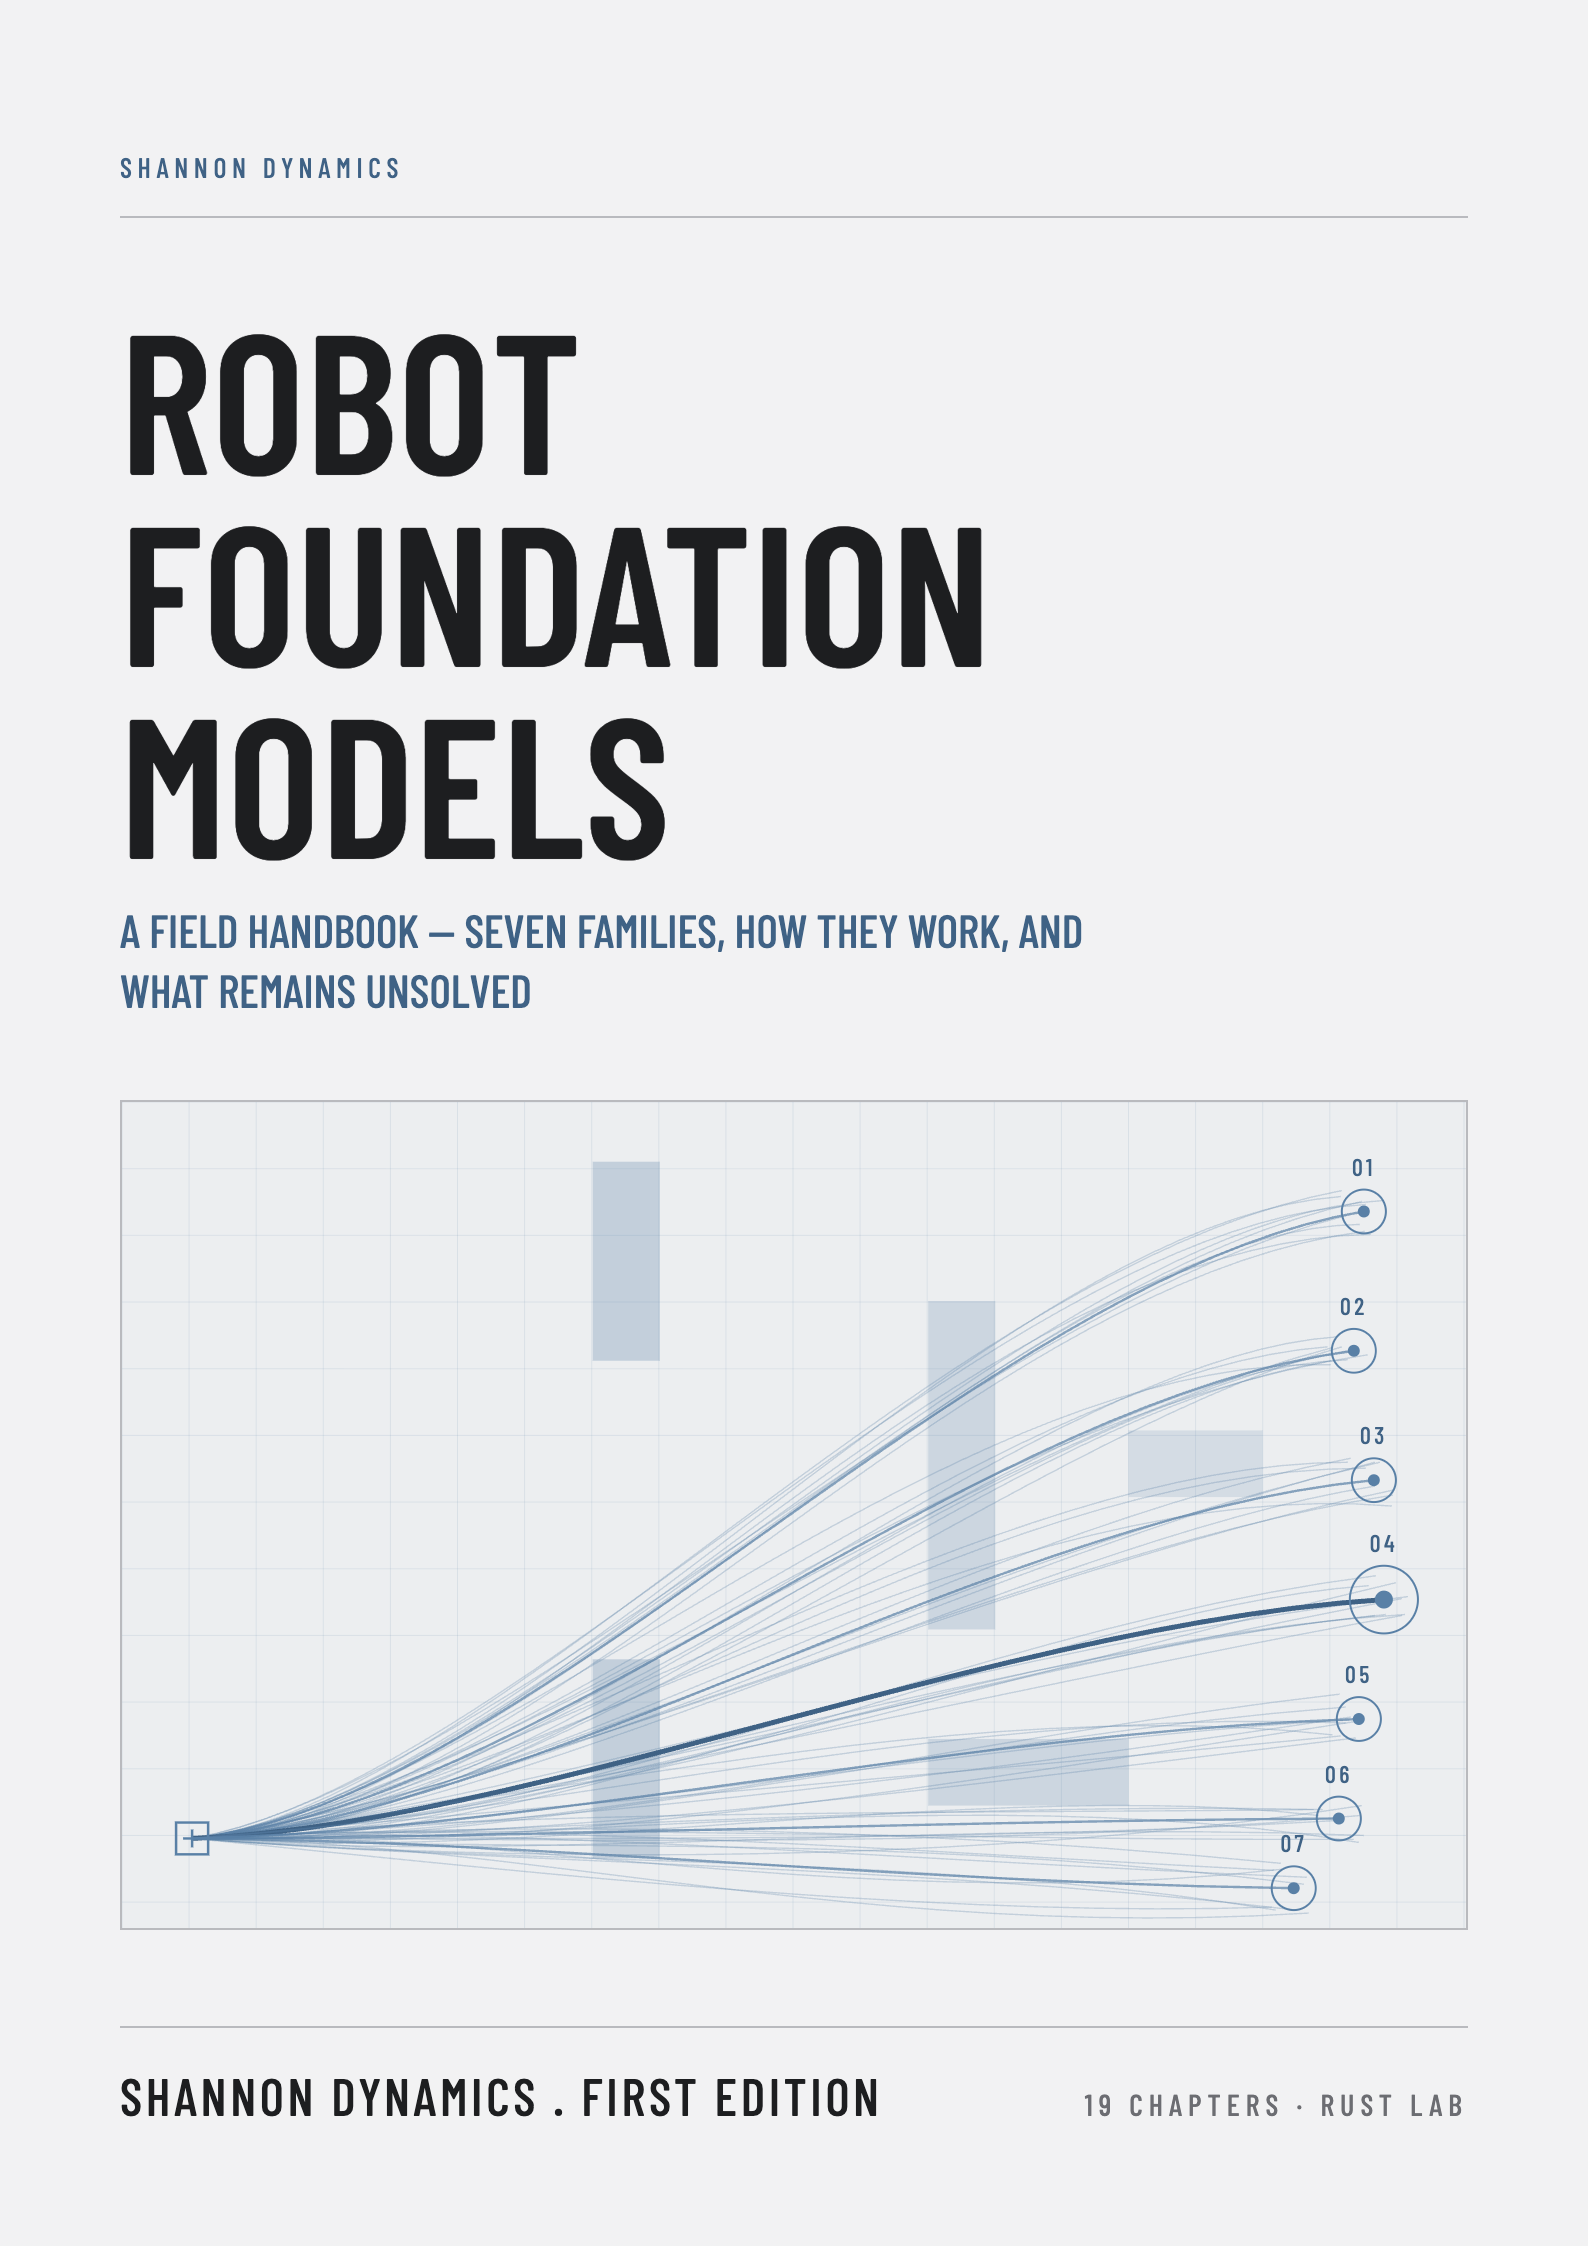
A field handbook to robot foundation models — seven families, how they work, and what remains unsolved — with interactive figures, sourced quotes and a tested Rust lab for every chapter.